UAS Systems Engineer · PX4 Firmware & Drone Autonomy · PhD Researcher at BME
Robotics and UAS Engineer with 8+ years of experience across the full drone development cycle — firmware, autonomy, hardware integration, and cloud telemetry. Specializing in PX4, ROS 2, and Auterion SDK; PhD researcher at BME — advancing UAS navigation in complex and GPS-degraded environments.
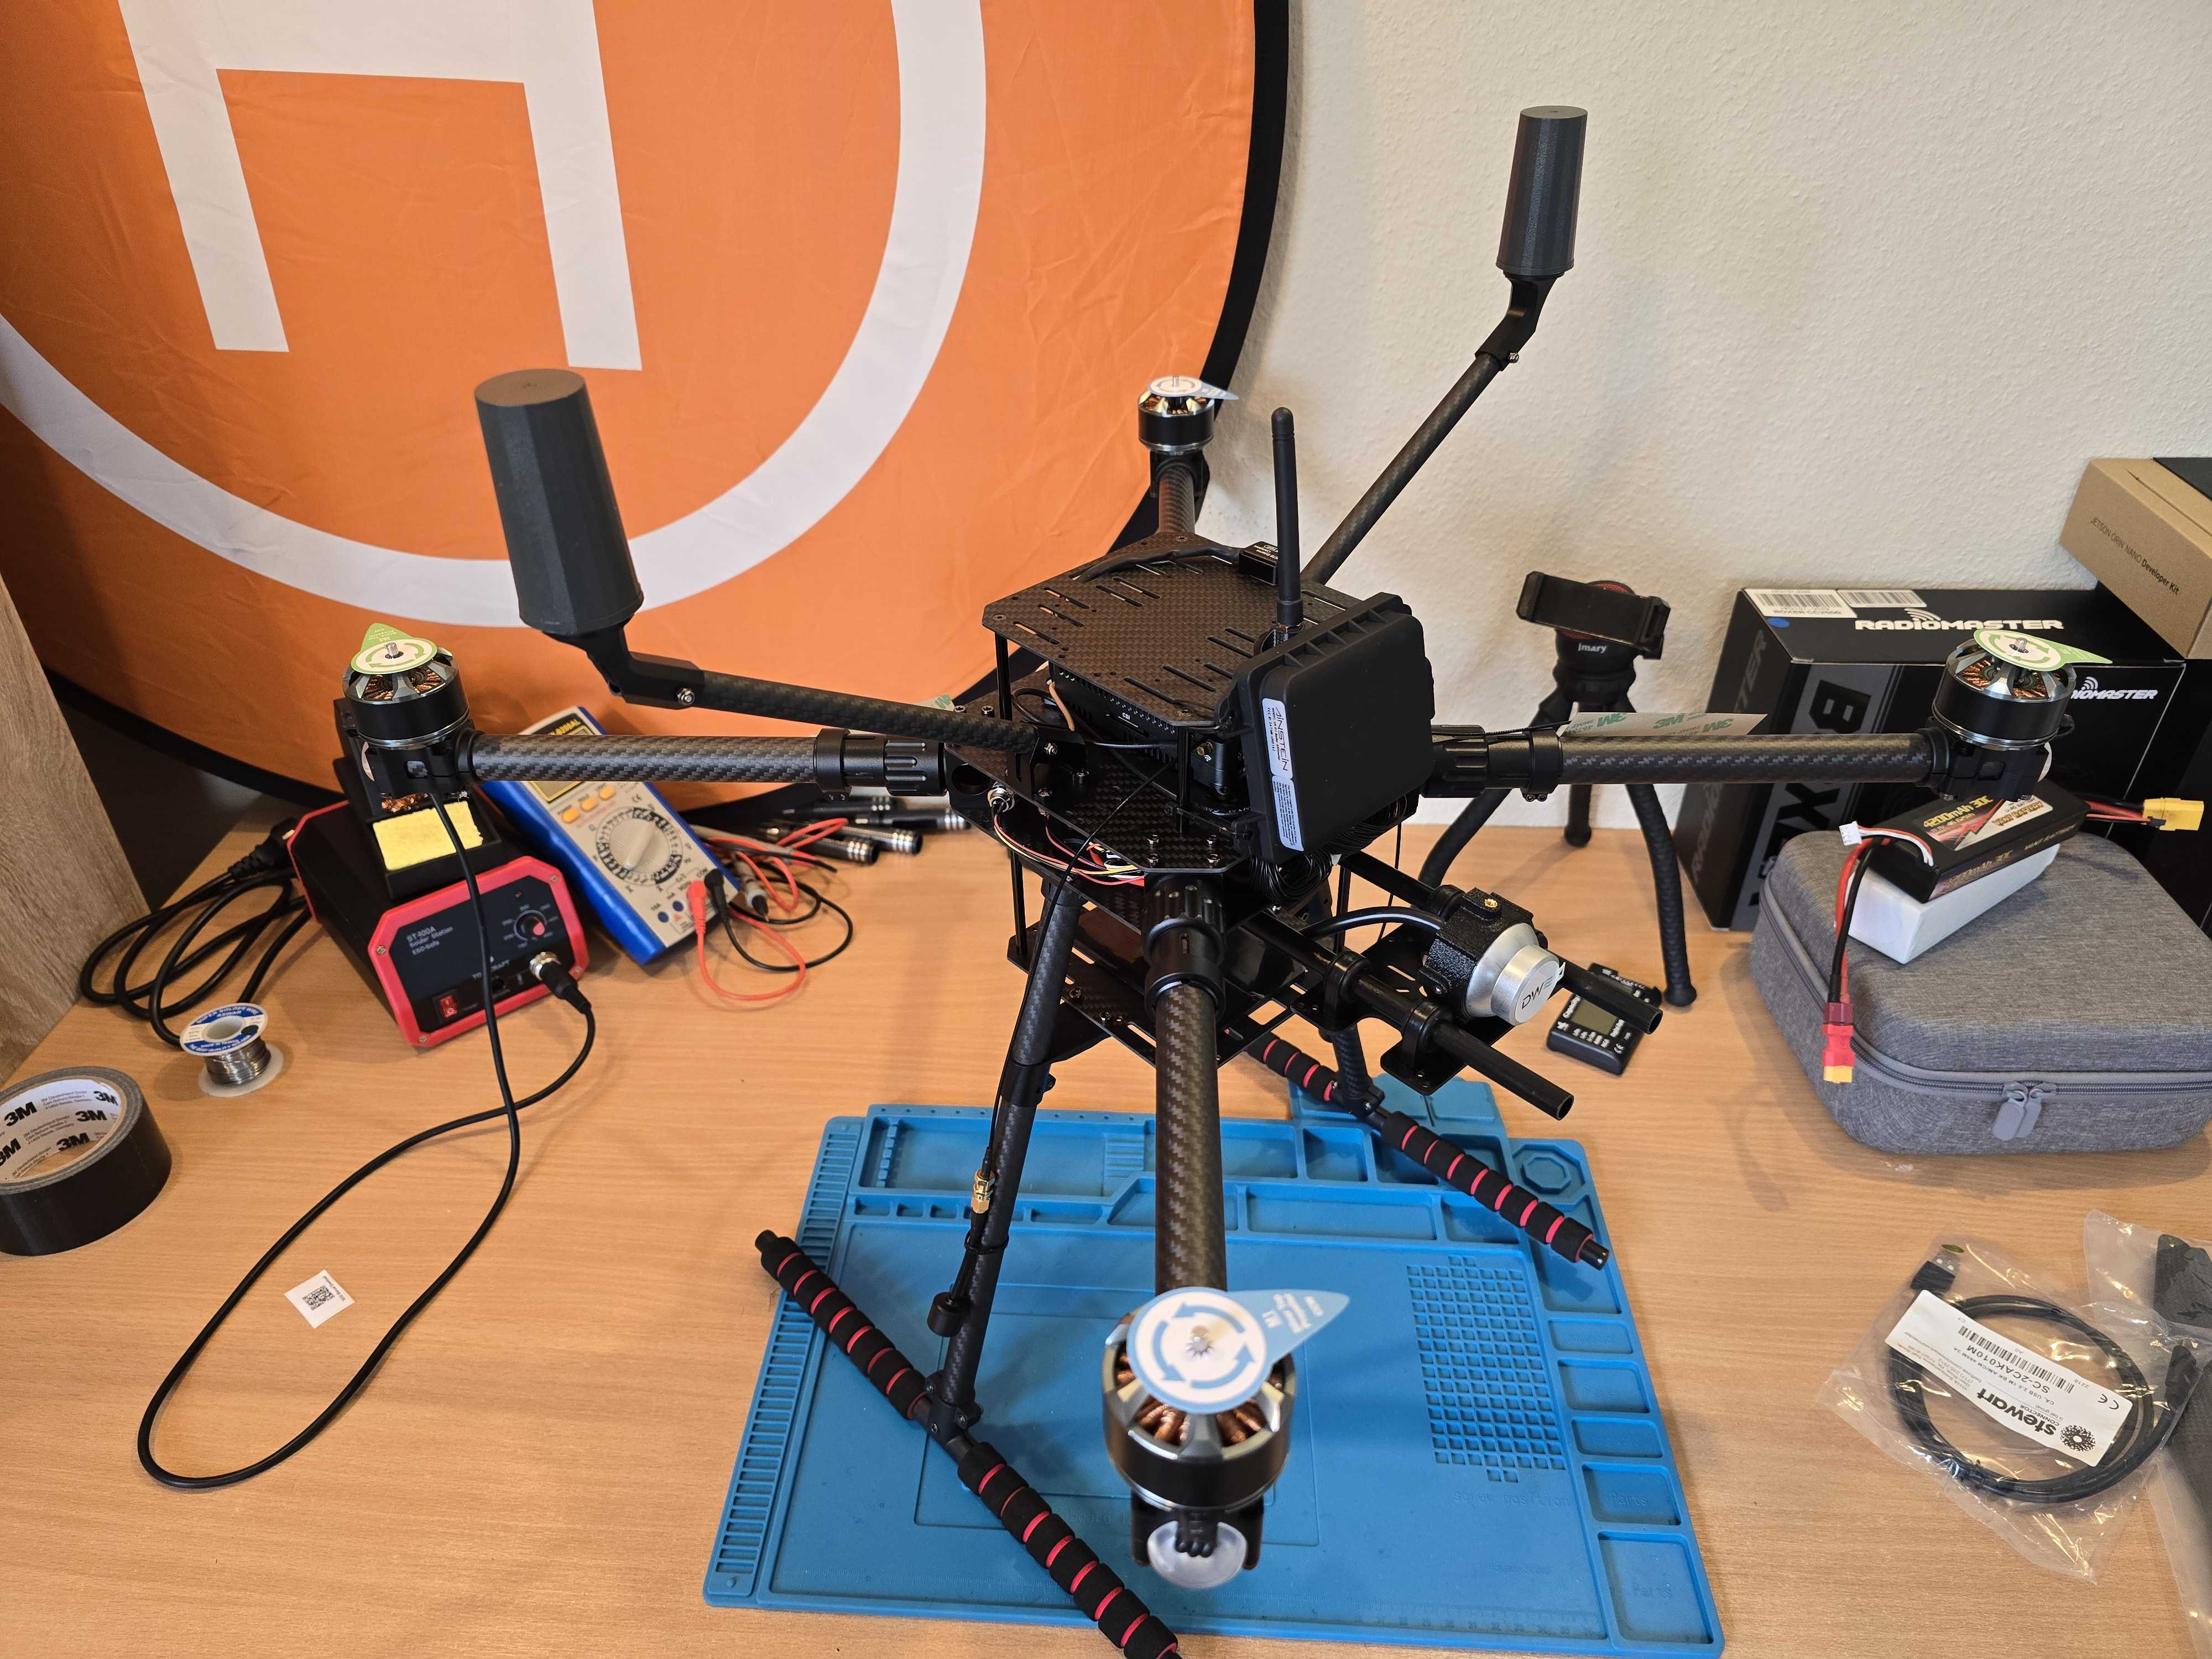
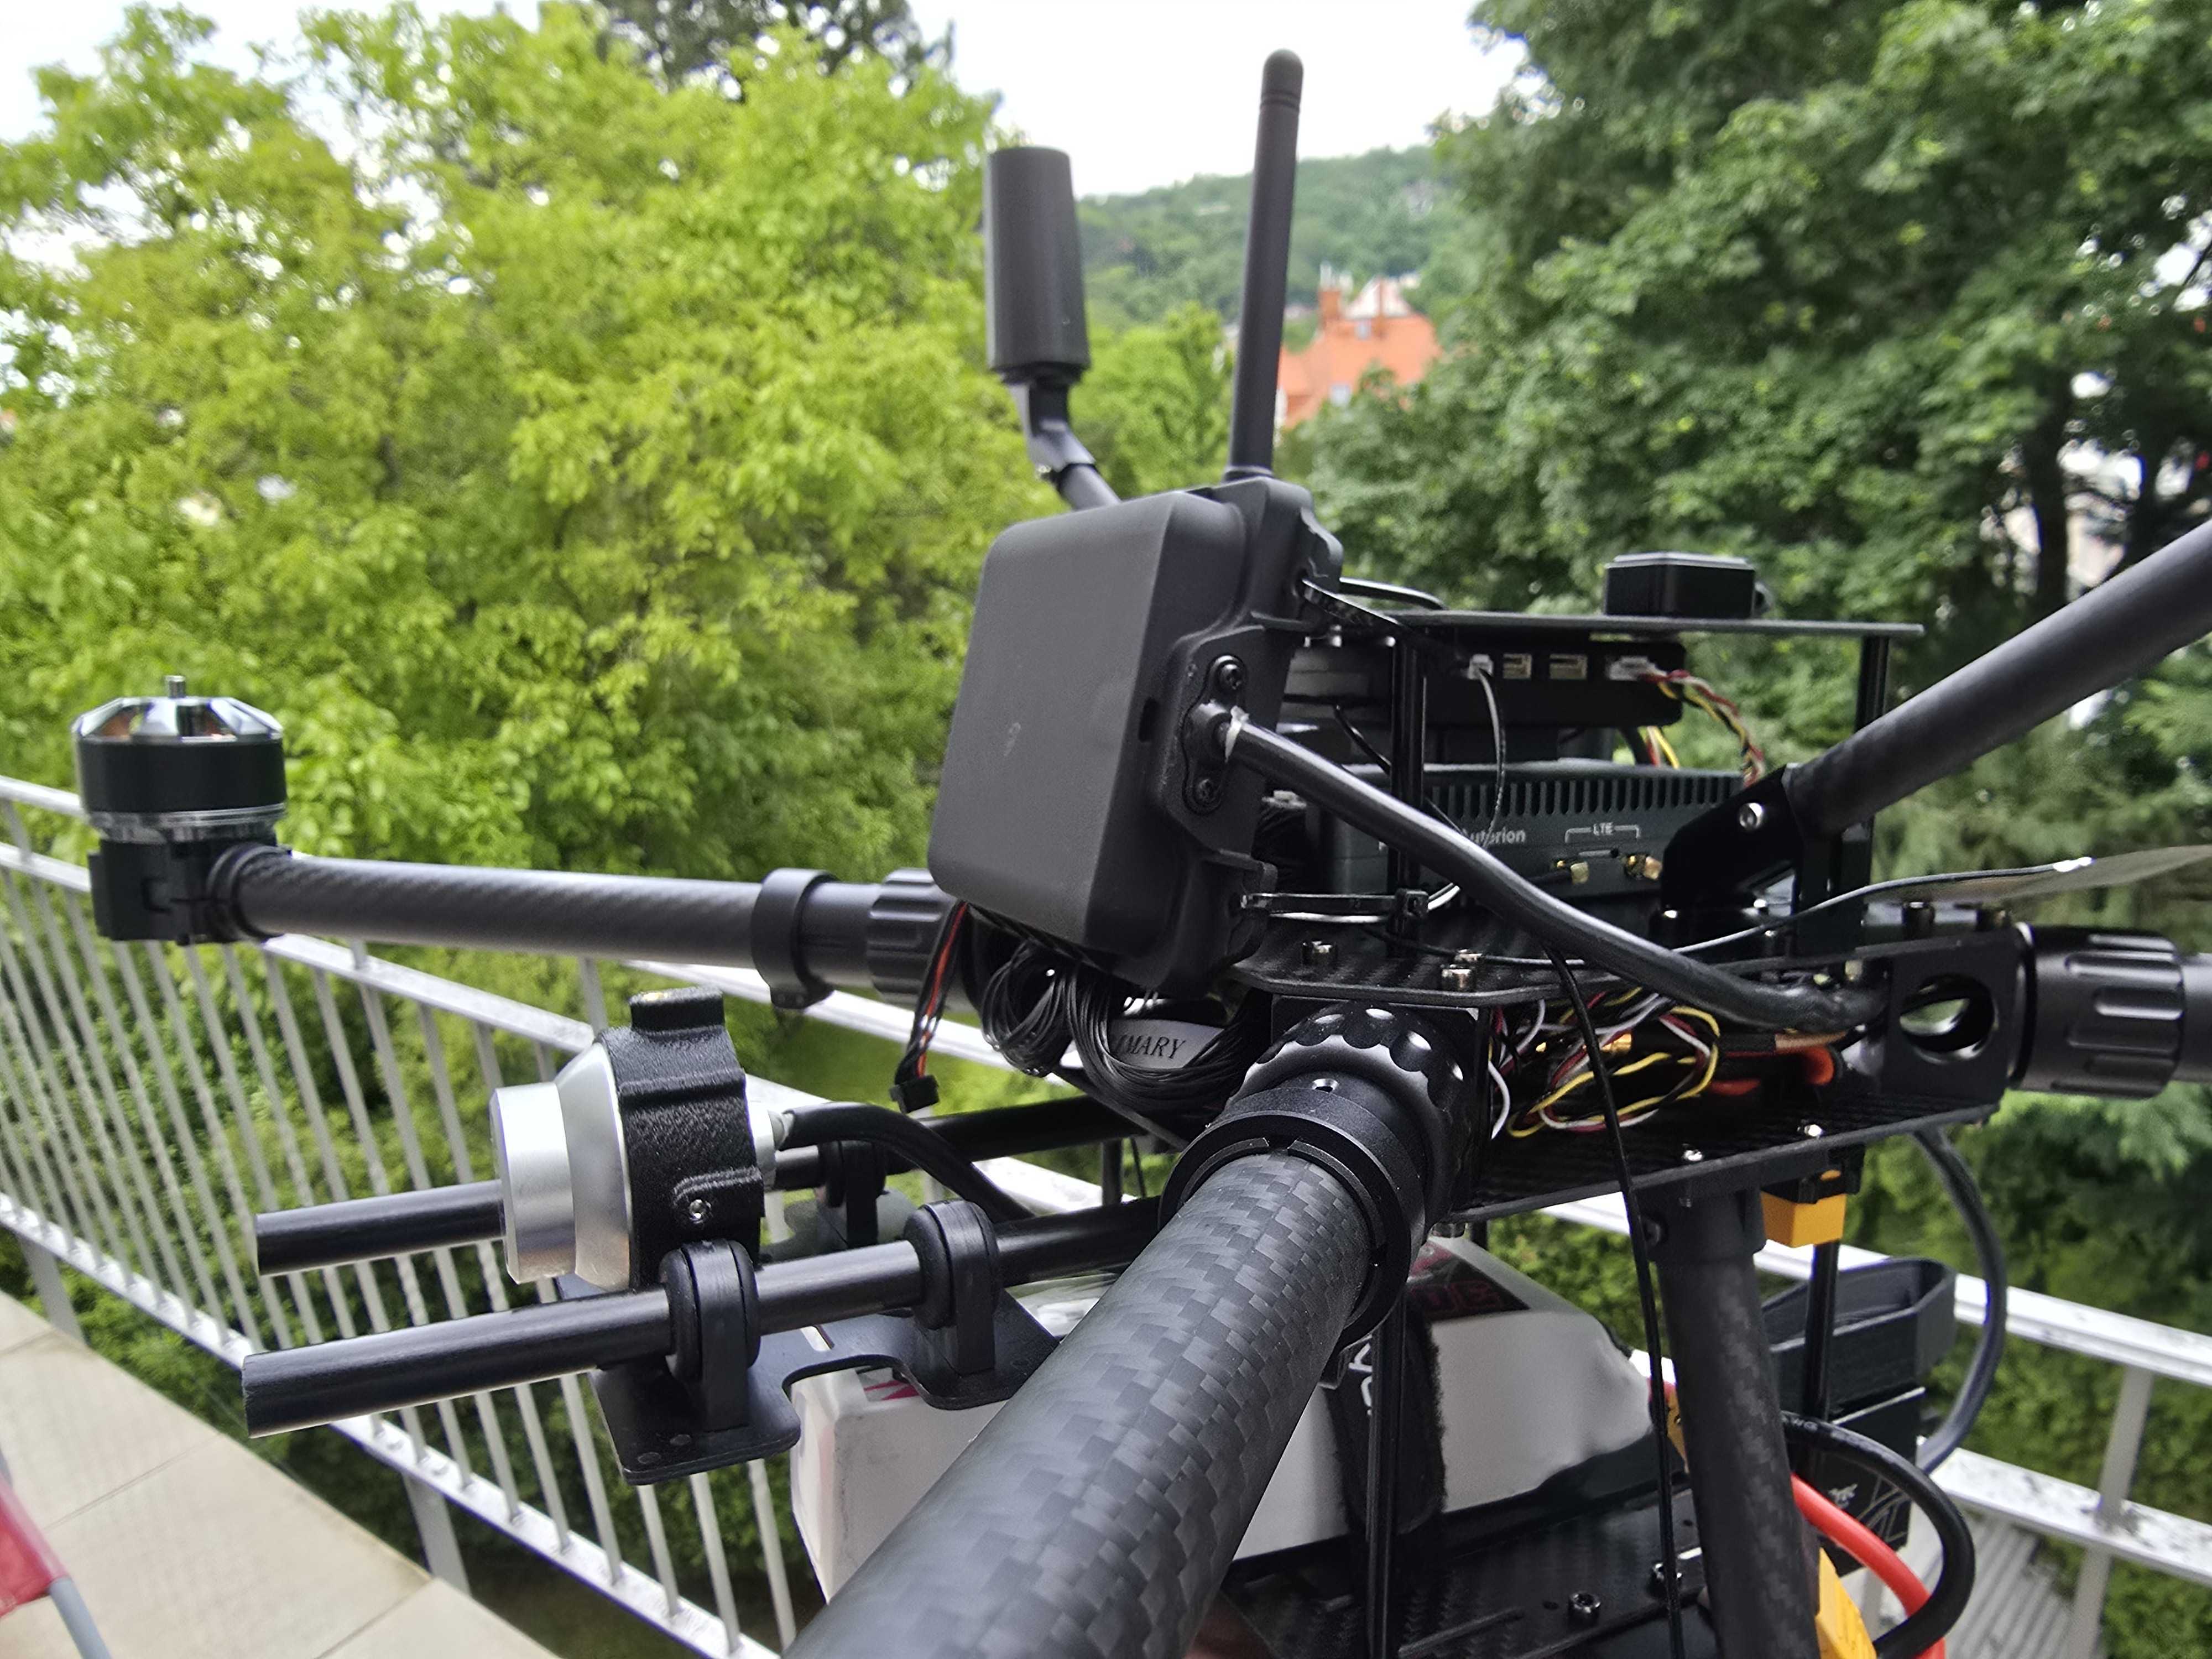
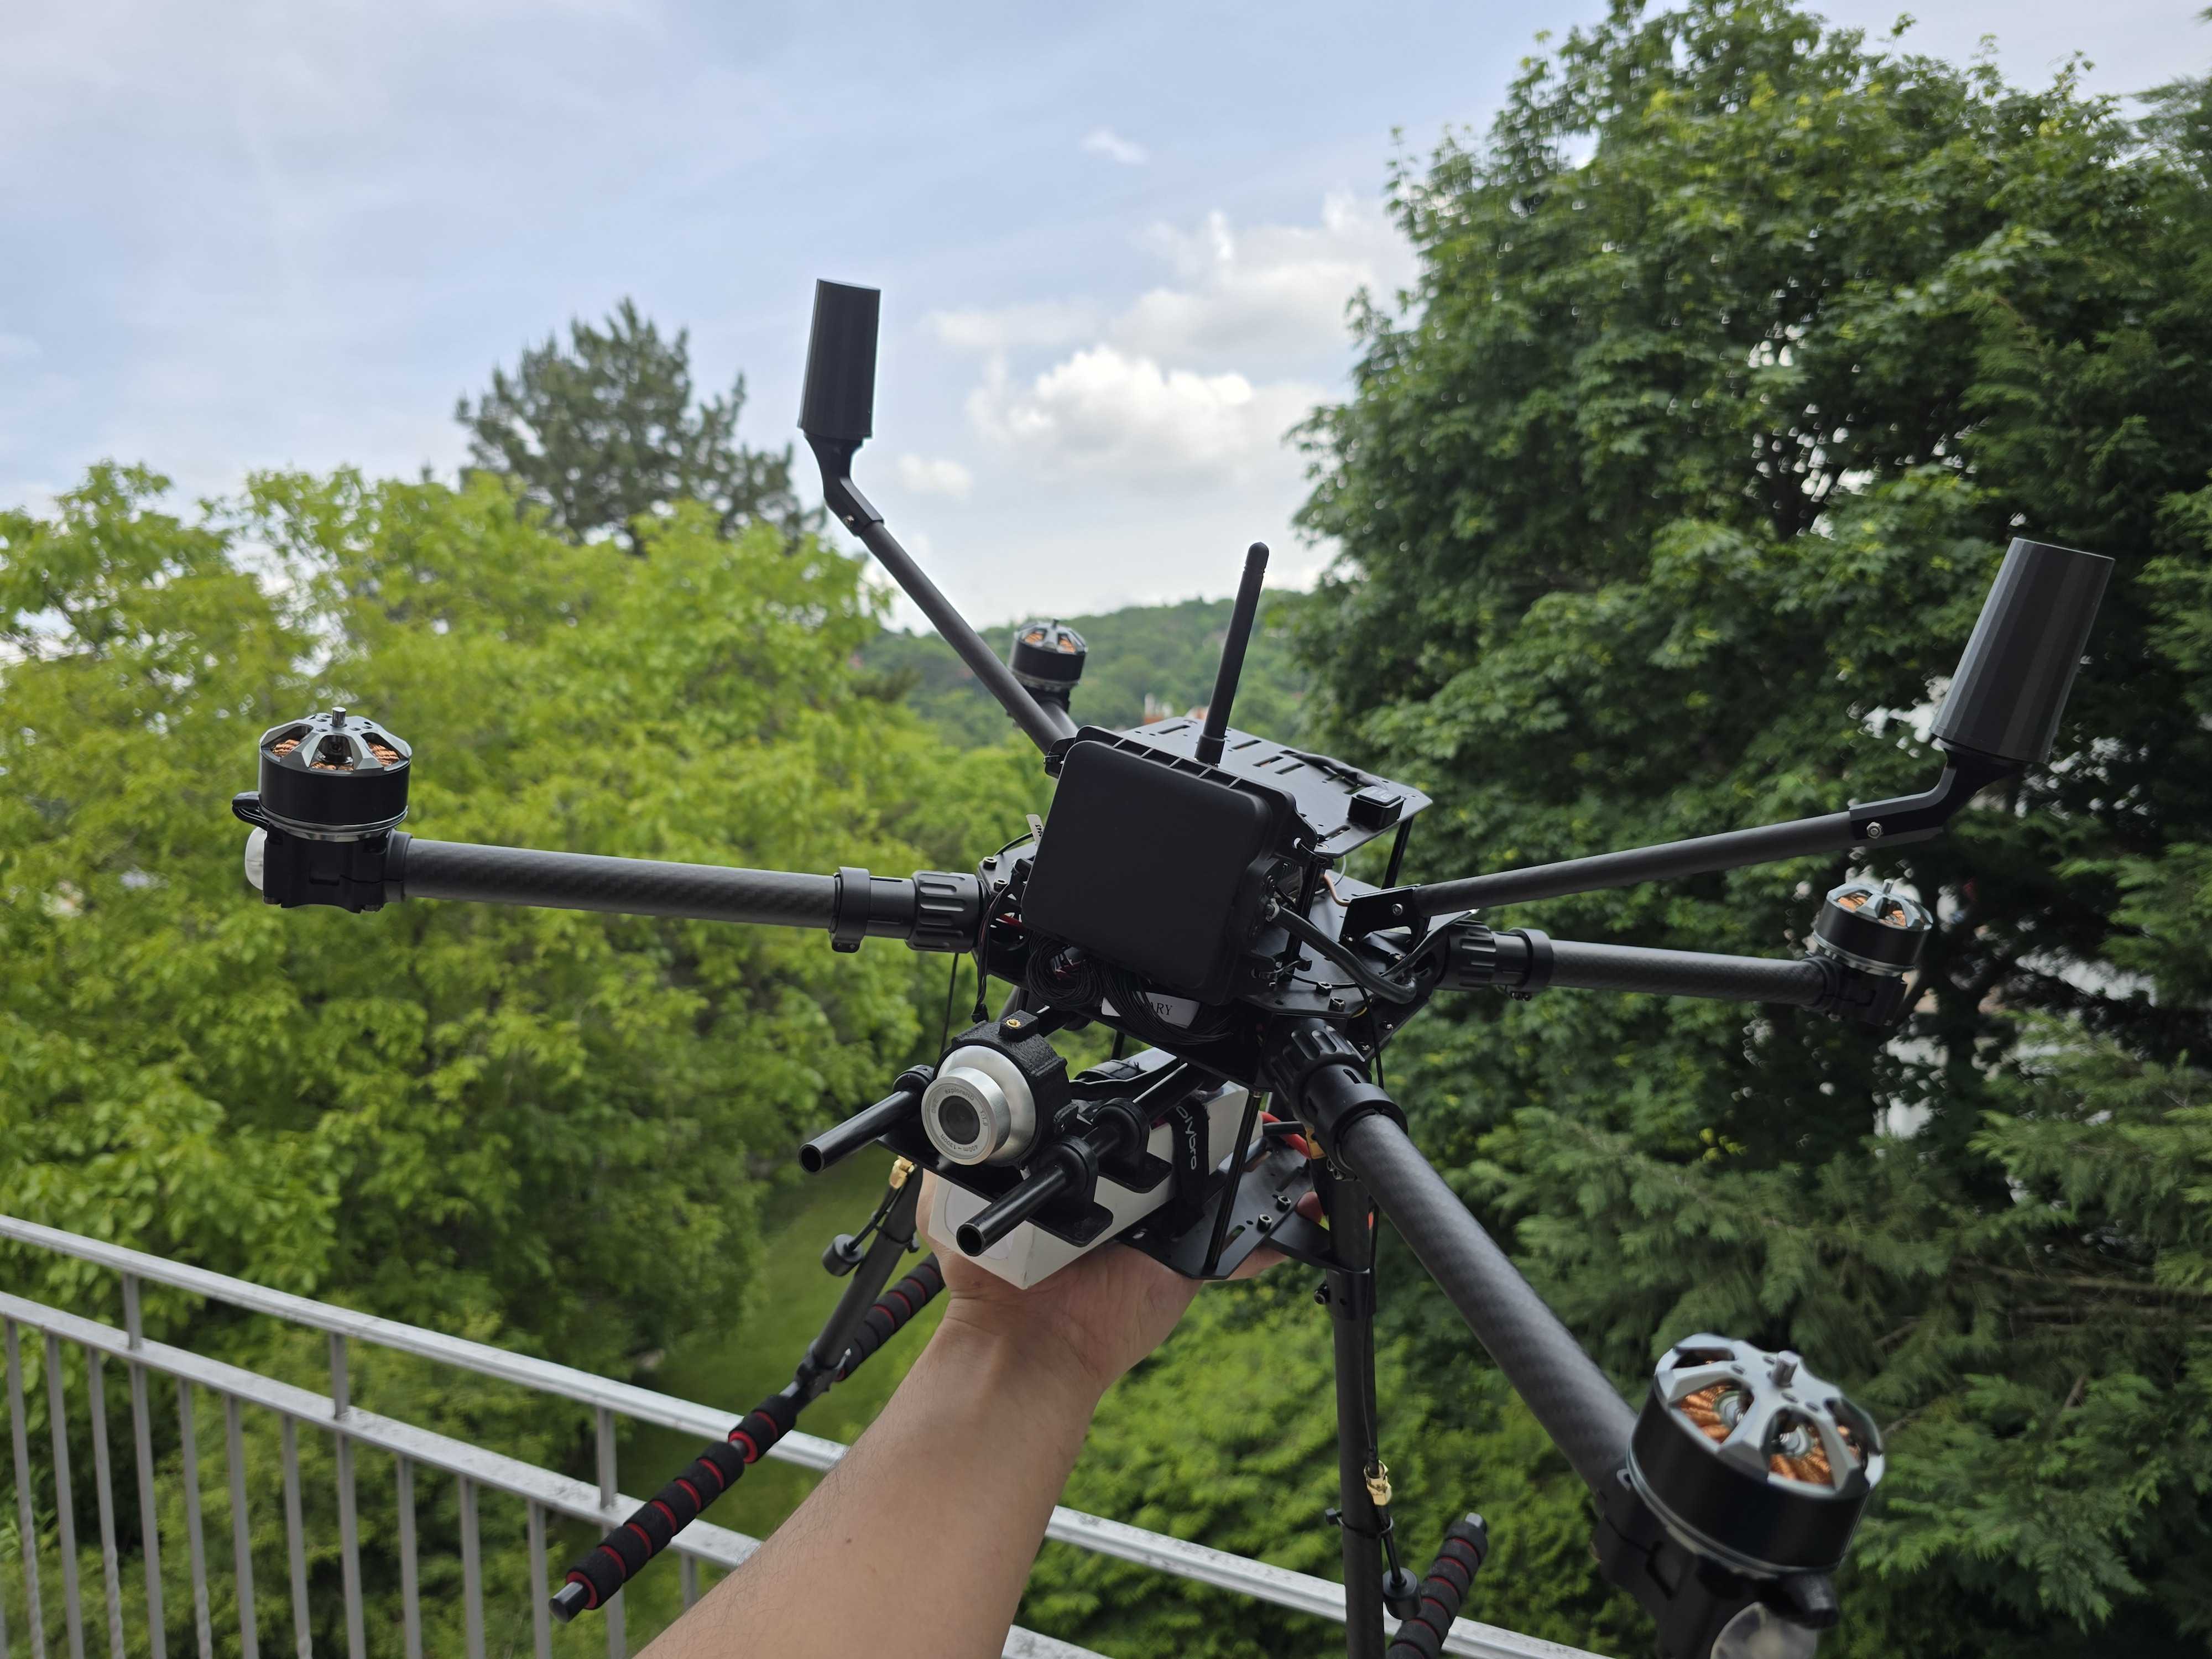
Autonomous building facade-cleaning flight mode for the Sherpa industrial drone.
Built using Auterion SDK (C++), it replaced fully manual piloting — operators clean
an entire facade end-to-end with a single button press.
Validated via SITL and SIH simulation (demo on left) before field deployment.
Phase 2 introduced LiDAR-based distance locking for constant 3 m standoff from facades.
ROS 2/Docker application streaming real-time flight telemetry from Skynode to AWS at ~115 msg/sec with zero message drops. Integrates Kinesis Data Streams, IoT Core (MQTT heartbeat), and S3 storage. Deployed as an AOS containerized app.
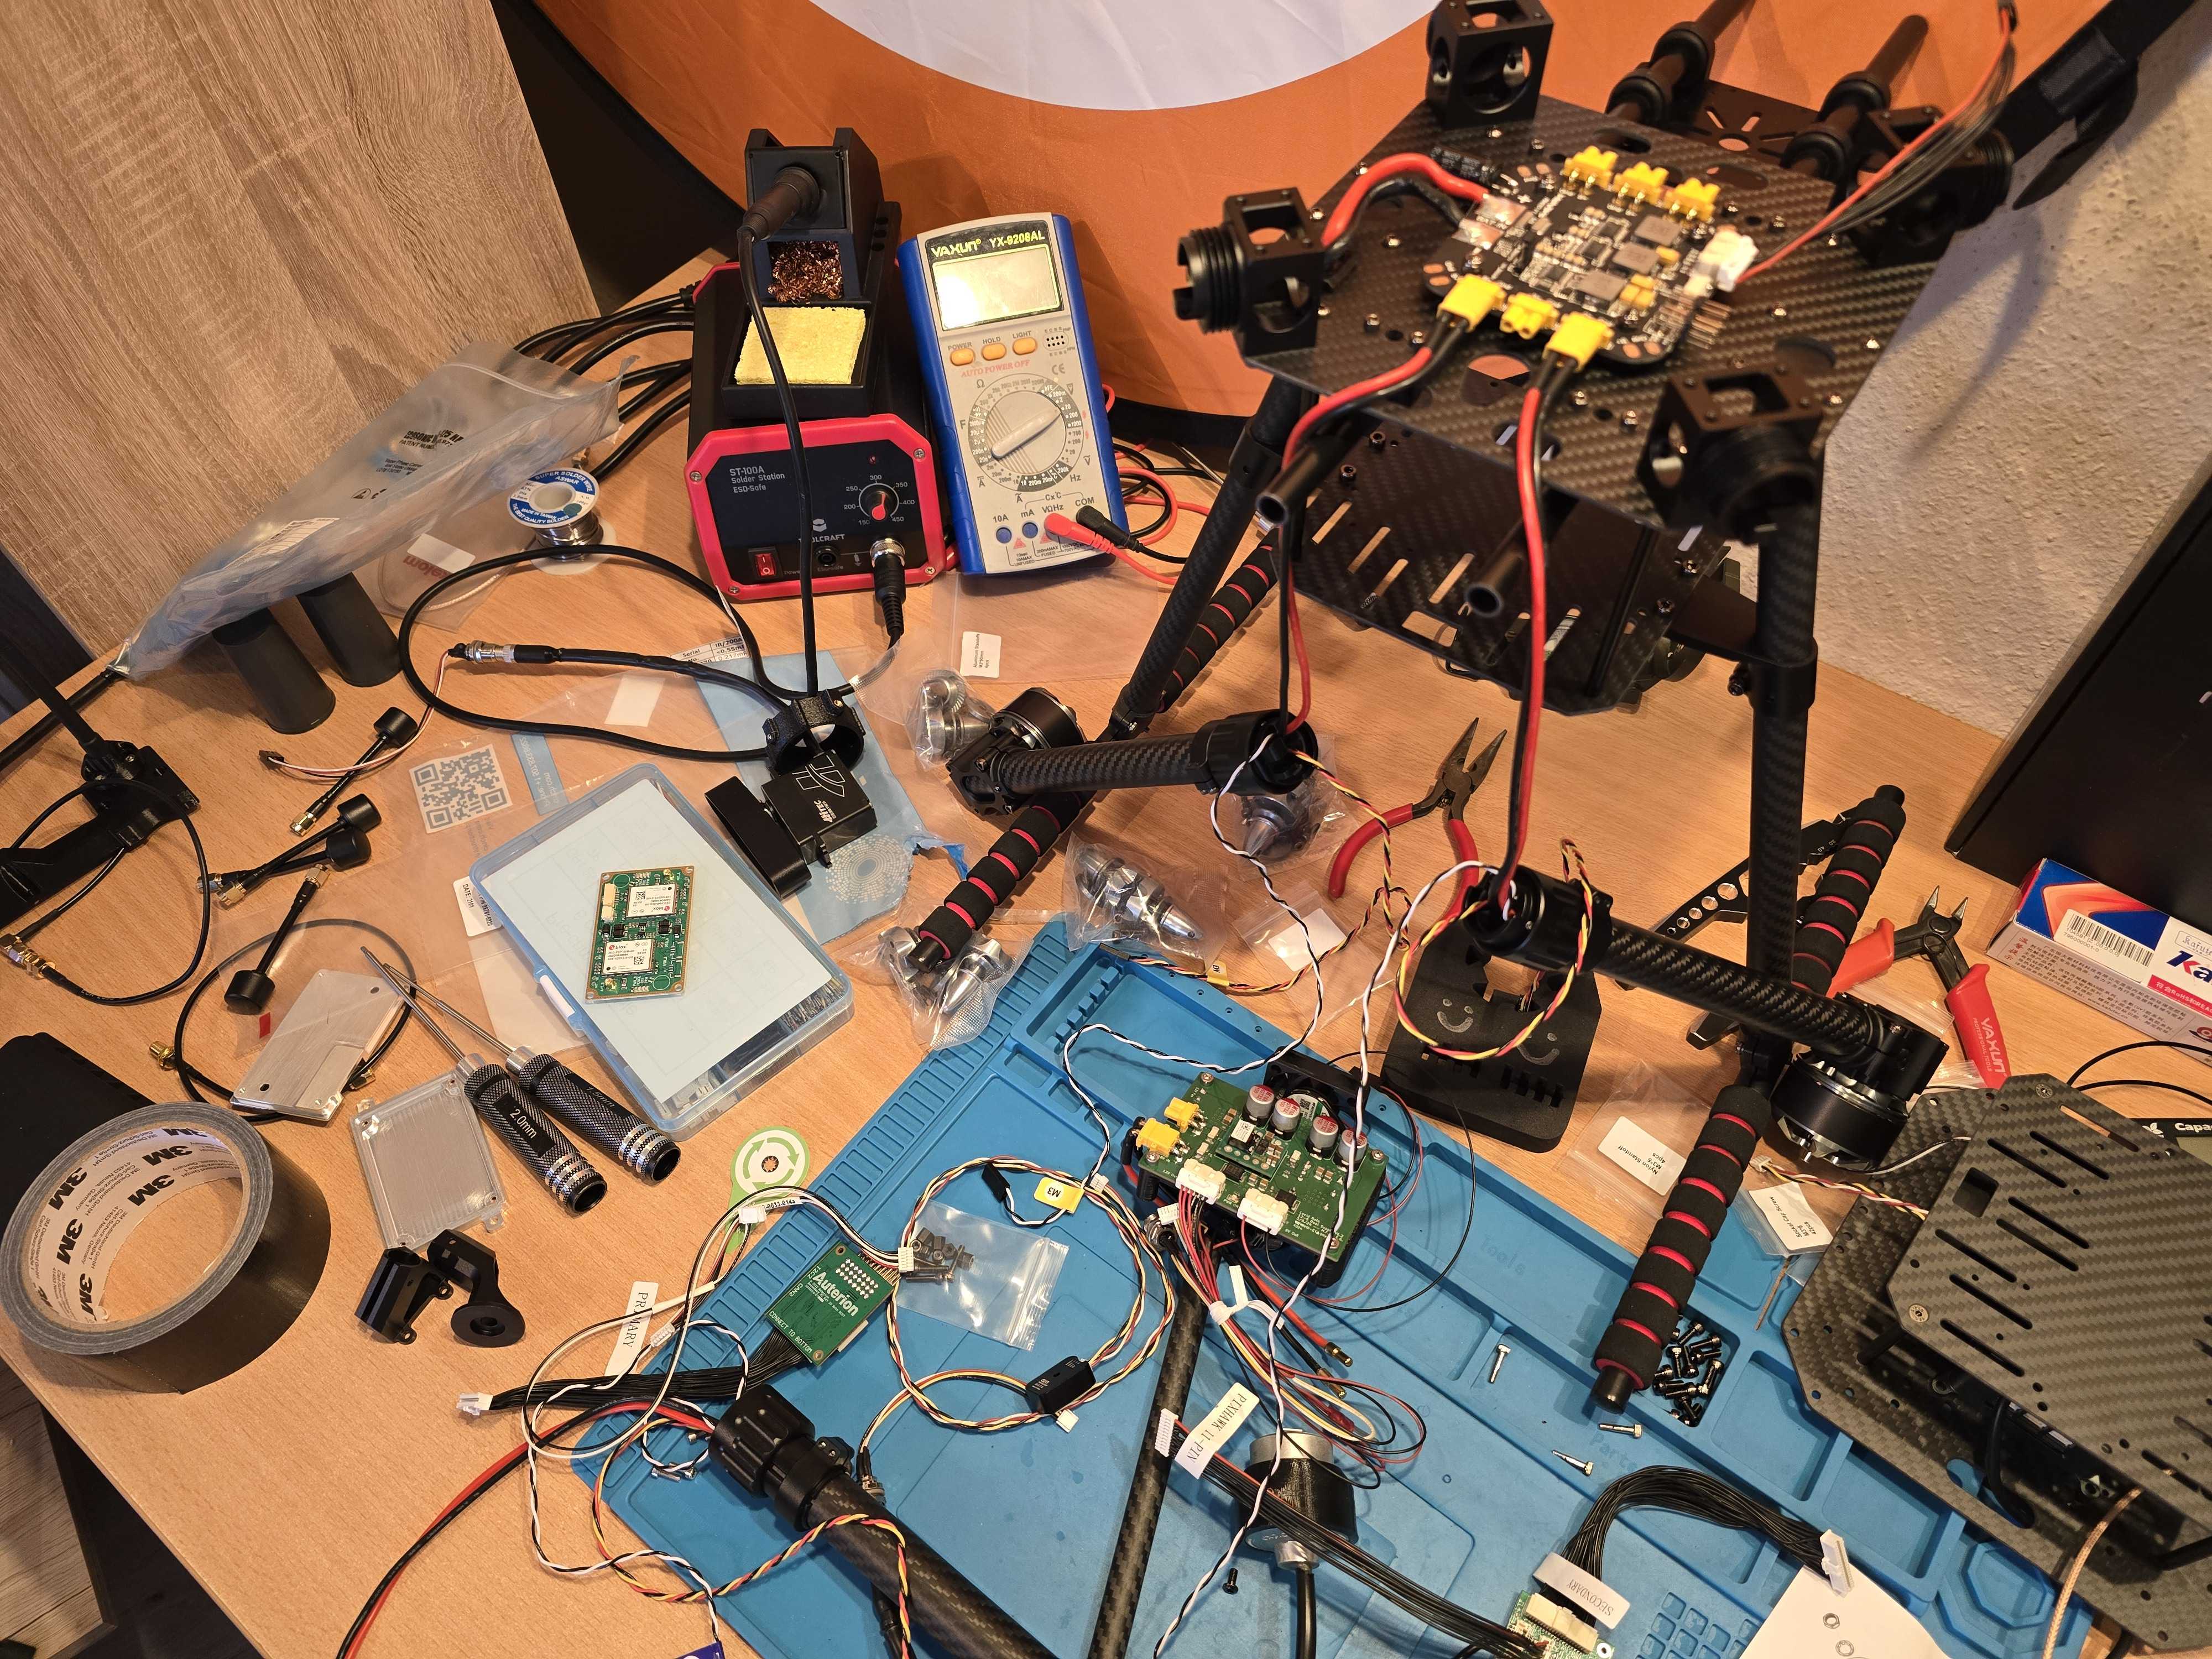
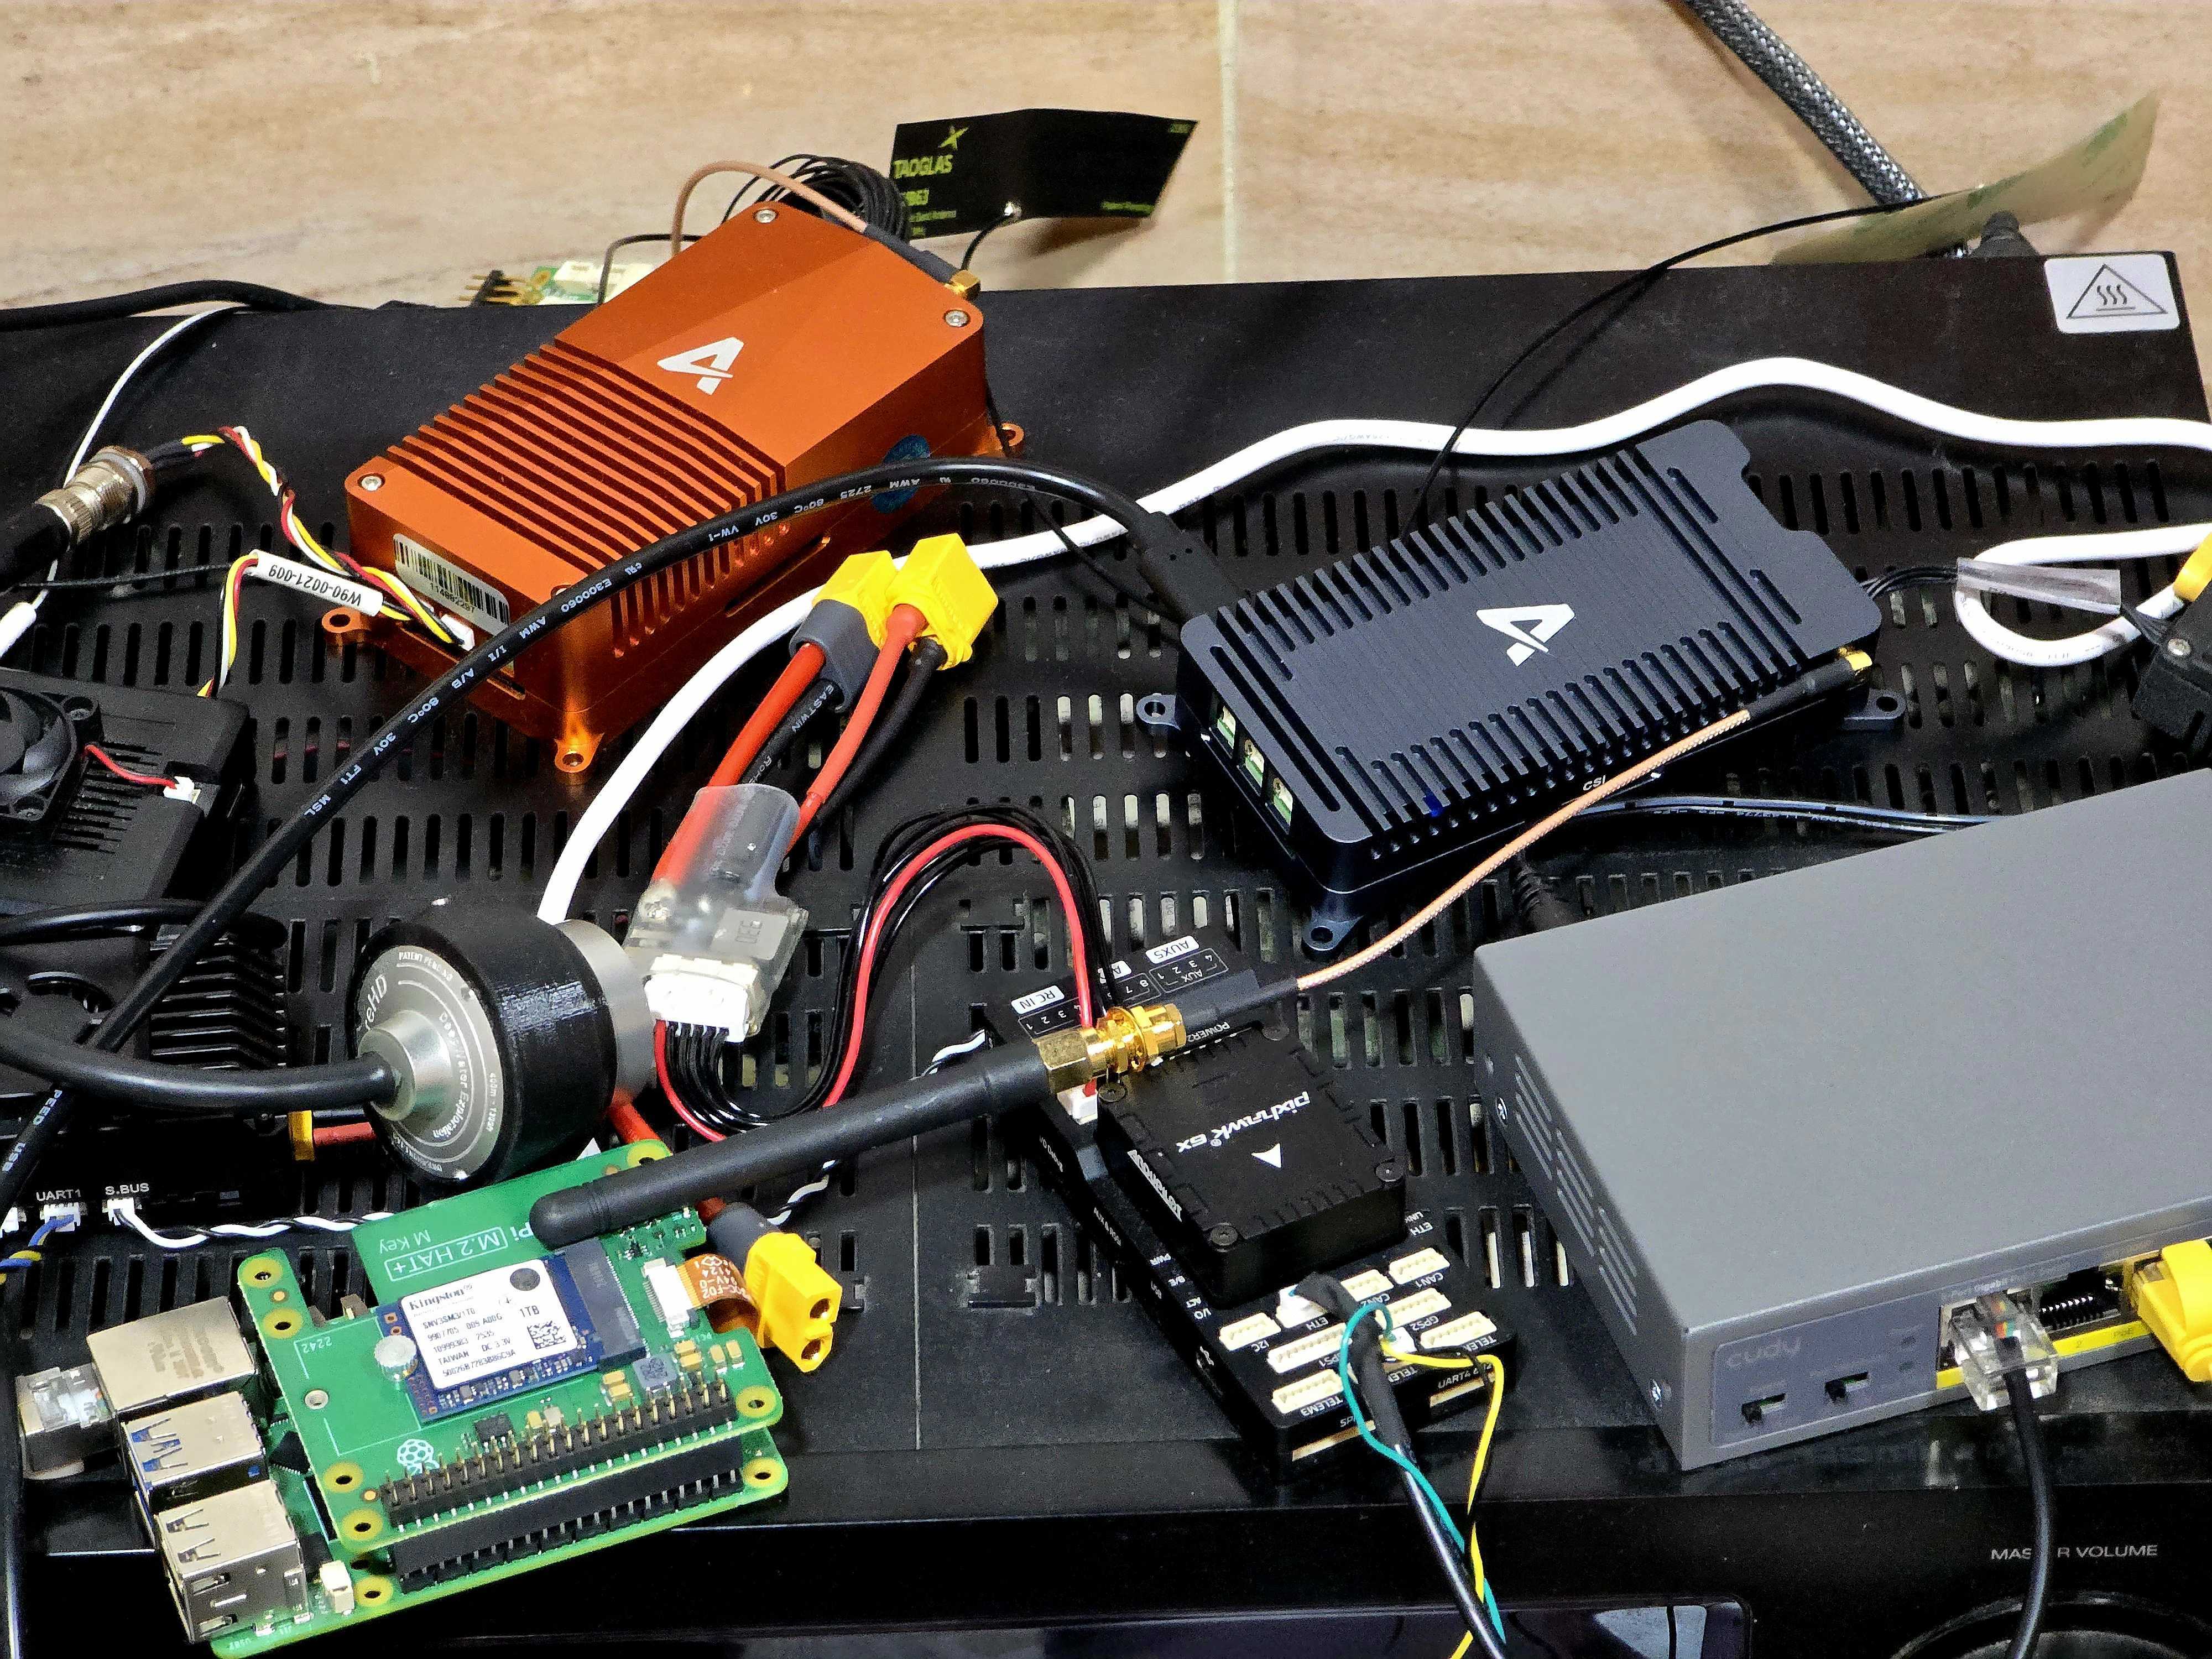
Architected the full onboard communication stack for a next-gen industrial drone platform — bridging MAVLink to a SIYI UniRC ground station (QGC), and uXRCE-DDS to ROS 2 on Raspberry Pi 5 over a shared Ethernet backbone. Defined message routing, interface contracts, and middleware configuration for a tightly integrated autonomy stack.
Fixed critical EKF2 GNSS yaw test failures in Lucid's private PX4 fork and modified GPS heading fusion logic for reliability near magnetically-interfered environments. Managed 5+ firmware releases with full QA on Skynode X and Skynode Orange.
AOS application for recording Sherpa FPV camera streams and uploading footage to AWS S3 without affecting AMC or Suite video. Deployable fleet-wide across Sherpa 1.0/1.5. Stops on disarm, handles file lifecycle and upload management.
Data-driven analysis of the global drone startup ecosystem — 698 companies across 40+ countries, segmented by industry focus. Geographic distribution, segment share, and key market takeaways.
View InsightsPatented system for controlling vehicle speed based on authorized speed limits using IoT infrastructure. Enables automatic, location-aware speed enforcement via real-time IoT communication between vehicles and road infrastructure.
Capabilities
Design and implementation of full autonomy stacks — mission logic, offboard control, multi-sensor state estimation, and onboard decision-making. Built on PX4, ROS 2, and Auterion SDK for production-grade platforms.
End-to-end integration of custom UAS platforms — airframe design, payload systems, companion computer setup, sensor suites, and communication architecture. From prototype to flight-ready system.
Rigorous real-world flight validation — firmware regression testing, failure mode analysis, performance characterization, and safety verification. Experienced with Skynode, PX4 SIH/HITL, and production field deployments.
Bridging PX4 flight control with ROS 2 autonomy stacks — uXRCE-DDS middleware setup, DDS topic mapping, Ethernet network architecture, simulation environments, and custom message definitions.
Deep-dive incident analysis from ULog data — reconstructing failure timelines, diagnosing EKF2 instability, yaw divergence, vibration anomalies, sensor drop-outs, and motor faults with root cause reports.
Design and deployment of real-time telemetry pipelines from drone to cloud — ROS 2 data ingestion, AWS Kinesis/IoT Core/S3, containerized AOS app deployment, and fleet monitoring systems.
Independent review of UAS system architecture, autonomy stack decisions, firmware strategy, and deployment readiness. Structured technical assessment with actionable recommendations before committing to production.
Consulting & Advisory
Working with startups, robotics teams, and industrial UAS companies on autonomy, firmware, and field deployment challenges. Whether you need hands-on engineering, architectural guidance, or an independent technical review — reach out and let's discuss your project.
Discuss your UAS engineering challenge — architecture decisions, firmware questions, autonomy design, or deployment strategy. Focused technical session with actionable output.
Ongoing technical advisory for robotics and UAS teams — system architecture reviews, R&D direction, firmware strategy, and second-opinion input at key decision points.
Direct engineering involvement in autonomy development, PX4 integration, flight validation, or telemetry infrastructure. Scope and terms defined per engagement.
Consultations available upon request · Rates depend on project scope and engagement type.